- Home
- Request for Quote
- Products
- Variable Frequency Drive Systems and Controls
- AC Variable Frequency Drives
- ABB ACS150 Component Drives :: Overview
- ABB ACS150 Component Drives :: Technical Specifications
- ABB ACS150 Component Drives :: Ratings, Types, Voltages and Construction – Prices
- ABB ACS150 Component Drives :: Dimensions, Weight and Noise
- ABB ACS150 Component Drives :: Interface and Options (prices)
- ABB ACS150 Component Drives :: Technical Data
- ABB ACS150 Component Drives :: Control Connections
- ABB ACS350 General Machinery Drives :: Overview
- ABB ACS350 General Machinery Drives :: Technical Specifications
- ABB ACS350 General Machinery Drives :: Ratings, Types, Voltages and Construction
- ABB ACS350 General Machinery Drives :: Dimensions, Weight and Noise
- ABB ACS350 General Machinery Drives :: Interface and Options (prices)
- ABB ACS350 General Machinery Drives :: Technical Data
- ABB ACS350 General Machinery Drives :: Control Connections
- ABB ACS550 AC Variable Frequency Drive :: Overview
- ABB ACS550 AC Variable Frequency Drive :: Hardware Description
- ABB ACS550 AC Variable Frequency Drive :: Standard Features and Options
- ABB ACS550 AC Variable Frequency Drive :: Specifications
- ABB ACS550 AC Variable Frequency Drive :: 230V Ratings (pricing)
- ABB ACS550 AC Variable Frequency Drive :: 380V Ratings (pricing)
- ABB ACS550 AC Variable Frequency Drive :: 480V Ratings (pricing)
- ABB ACS550 AC Variable Frequency Drive :: Dimensions: ACS550 NEMA 1 R1 through R6 Frame Size
- ABB ACS550 AC Variable Frequency Drive :: Dimensions: ACS550 NEMA 12 R1 through R6 Frame Size
- ABB ACS550 AC Variable Frequency Drive :: Dimensions: ACS550-02 NEMA 1 R7 Frame Size
- ABB ACS550 AC Variable Frequency Drive :: Dimensions: ACS550-02 NEMA 1 R8 Frame Size
- ABB ACS550 AC Variable Frequency Drive :: Dimensions: ACS550-U2 NEMA 1 R7 & R8 Frame Size
- ABB ACS 600 Adjustable Speed AC Drives
- ABB ACS800 AC Variable Frequency Drive :: Overview
- ABB ACS800 AC Variable Frequency Drive :: Standard Features / Available Options and Software
- ABB ACS800 AC Variable Frequency Drive :: Specifications
- ABB ACS800 AC Variable Frequency Drive :: Basic Type Code Information
- ABB ACS800 AC Variable Frequency Drive :: 230V Ratings (pricing)
- ABB ACS800 AC Variable Frequency Drive :: 380V Ratings (pricing)
- ABB ACS800 AC Variable Frequency Drive :: 460V Ratings (pricing)
- ABB ACS800 AC Variable Frequency Drive :: ACS 800-U2 NEMA 1 R7 & R8 Frame Size and ACS 800-02+C111 IP21 (NEMA 1) R7 & R8 Frame Size
- ABB ACS800 AC Variable Frequency Drive :: ACS 800 NEMA 1/12 R2 through R6 Frame Size
- ABB ACS800 AC Variable Frequency Drive :: ACS 800-02 NEMA 1 R7 & R8 Frame Size
- ABB ACS800 AC Variable Frequency Drive :: ACS 800-U4 Module R7 Frame Size
- ABB ACS800 AC Variable Frequency Drive :: ACS 800-U4 Module R8 Frame Size
- ABB ACS880 Industrial Low Voltage AC Drives
- ABB ACS880 AC Drives – Technical Data
- Wall-mounted single drives, ACS880-01
- ABB ACS880 Ratings, types and voltages
- ABB ACS880 AC Drives – Dimensions & Connectivity
- ABB ACS880 AC Drives – Standard Software
- ABB ACS880 AC Drives – Intuitive Human-Machine Interface
- ABB ACS880 AC Drives – Integrated Safety
- ABB ACS880 AC Drives – Flexible Connectivity
- Input/output Modules, Speed Feedback Interfaces & Communication Modules
- ABB Softstarters, Type SSM, Medium Voltage, 2300-13,800V :: Description
- ABB Type SSM Softstarters – Medium Voltage, 2300-13,800V :: General Information
- ABB Type SSM Soft Starters – Medium Voltage, 2300 – 13,800V :: Catalog Numbers
- ABB Soft Starters, Type SSM – Medium Voltage, 2300-13,800V :: Technical Data
- ABB Softstarters, Type SSM, Medium Voltage, 2300-13,800V :: Approx. Dimensions
- Yaskawa AC Drives
- AuCom Soft Starters
- Emerson Industrial Automation (Control Techniques and Saftronics) AC Drives
- Control Techniques – Commander SE AC Drive
- Control Techniques – Commander SK AC Drive
- Commander SK :: Features
- Commander SK :: Terminal Diagram and Description
- Commander SK :: Specifications and Dimensions
- Commander SK – Options :: Overview
- Commander SK – Options :: Configuration and Programming
- Commander SK :: Operator Interface
- Commander SK :: Power Accessories
- Commander SK :: Environmental Protection and Cable Management
- Commander SK :: Input / Output
- Commander SK :: Communication
- Commander SK :: Programming Software
- Control Techniques – Commander SX AC Drive
- Commander SX :: Features, Ratings, Prices and Ordering
- Commander SX :: Terminal Diagram and Description
- Commander SX:: Specifications and Dimensions
- Commander SX :: Options – Overview / Drive Configuration and Programming
- Commander SX :: Communication / Operator Interface
- Commander SX :: Power Accessories
- Commander SX :: Input/Output and Communication
- Control Techniques – Unidrive SP AC Drive
- Unidrive SP :: Features
- Unidrive SP :: Ratings, Prices & Ordering – Wall Mount
- Unidrive SP :: Ratings, Prices & Ordering – Free Standing Cubicle
- Unidrive SP :: Unidrive SP Regen Mode
- Unidrive SP :: Terminal Diagram and Description
- Unidrive SP :: Specifications and Dimensions
- Unidrive SP :: Options – Overview
- Unidrive SP :: Operator Interface
- Unidrive SP :: Power Accessories
- Unidrive SP :: Option & Feedback Modules
- Unidrive SP :: Option Input / Output Modules
- Unidrive SP :: Option Application / Programming Modules
- Unidrive SP :: Option Communication Modules
- Unidrive SP :: Drive Configuration and Programming
- Unidrive SP :: Application Programming Software
- Unidrive SP :: Pre-packaged Solutions
- Saftronics GP10 AC Drives
- Saftronics GP10 – Pricing, Dimensions & Weights
- Saftronics GP10 – Optional DC Link Reactors
- Saftronics GP10 – Options & Accessories
- Saftronics GP10 – Palm Pilot Saflink Kit
- Saftronics GP10 – SR10 Radio Modem Kit
- Saftronics GP10 – Relay Output Card
- Saftronics GP10 – Digital I/O Interface Card
- Saftronics GP10 – Analog I/O Interface Card
- Saftronics GP10 – SF-10 Ethernet Module
- Saftronics GP10 – Interface Option Card
- Saftronics GP10 – Under Torque Detection Option
- Saftronics GP10 – 24 VDC or 24/120 VAC Interface
- Saftronics GP10 – Air Pressure Sensor + V/I Converter Output Card
- Saftronics GP10 – HMI Pump Controller
- Saftronics GP10 – SDBU – Dynamic Brake Module
- Saftronics GP10 – 208-230V Dynamic Brake Packages
- Saftronics GP10 – 460V Dynamic Brake Packages
- Saftronics GP10 – Ratings Efficiency & Watts Loss
- Saftronics GP10 – Standard Specifications
- Saftronics GP10 – Basic Connection Diagram
- Saftronics GP10 – Basic Connection Diagram to PLC
- Saftronics GP10 – Basic Connection Diagram (Europe)
- Saftronics GP10 – Basic Connection to PLC (Europe)
- Saftronics S10 AC Drives
- Saftronics S10 – Options and Accessories
- Saftronics S10 – Standard Specifications
- Saftronics S10 – Dimensions
- Saftronics S10 – Dimensions – Part Number: S102002 – S102003 & S104001 – S104003
- Saftronics S10 – Dimensions – Part Number: S102F25 – S102001
- Saftronics S10 – Dimensions — Part Number: S102F25 – S102001 no Operators
- Saftronics S10 – Dimensions – Part Number: S102002-2003 & S104001-4003
- Saftronics S10 – Basic Wiring Diagram
- Saftronics CV10 AC Drives
- Saftronics CV10 – Part Numbers, Dimensions & Weights
- Saftronics CV10 – LED Keypad with Speed Pot
- Saftronics CV10 – LCD Keypad (supports 5 Languages)
- Saftronics CV10 – Keypad Extension Cable
- Saftronics CV10 – Communication Option Cards
- Saftronics CV10 – Bi-Polar Speed Reference Option Card
- Saftronics CV10 – Standard Specifications
- Saftronics CV10 – Ratings Efficiency and Watts Loss
- Saftronics CV10 – Dimensions Frame 1 – IP20 (Open Chassis)
- Saftronics CV10 – Dimensions Frame 1 – NEMA 1
- Saftronics CV10 – Dimensions Frame 2 – IP20 (Open Chassis)
- Saftronics CV10 – Dimensions Frame 2 – NEMA 1
- Saftronics CV10 – Dimensions Frame 3 – IP20 (Open Chassis)
- Saftronics CV10 – Dimensions Frame 3 – NEMA 1
- Saftronics CV10 – Basic Wiring Diagram
- Saftronics VG10 AC Drive
- Saftronics VG10 – Pricing, Dimensions & Weights
- Saftronics VG10 – Optional DC Link Reactors
- Saftronics VG10 – Options and Accessories
- Saftronics VG10 – Palm Pilot Saflink Kit
- Saftronics VG10 – Relay Output Card
- Saftronics VG10 – SR10 Radio Modem Kit
- Saftronics VG10 – Digital I/O Interface Card
- Saftronics VG10 – Analog I/O Interface Card
- Saftronics VG10 – SF-10 Ethernet Module
- Saftronics VG10 – PGX Encoder Feedback Card
- Saftronics VG10 – Encoder + Analog Output Card
- Saftronics VG10 – PG Feedback Card SOPCG11SPG
- Saftronics VG10 – PG Feedback Card SOPCG11SPG2
- Saftronics VG10 – Synchronized Operation Card
- Saftronics VG10 – 24 VDC or 24/120 VAC Interface Card Kit
- Saftronics VG10 – Air Pressure Sensor + V/I Converter Output Card
- Saftronics VG10 – SDBU – Dynamic Brake Module
- Saftronics VG10 – 208-230V Dynamic Brake Packages
- Saftronics VG10 – 460V Dynamic Brake Packages
- Saftronics VG10 – Ratings Efficiency and Watts Loss
- Saftronics VG10 – Standard Specifications
- Saftronics VG10 – DC Link Reactor 100 HP and Above
- Saftronics VG10 – Basic Connection Diagram (Sink Logic, Mainly America)
- Saftronics VG10 – Basic Connection Diagram to PLC (Sink Logic, Mainly America)
- Saftronics VG10 – Basic Connection Diagram (Source Logic, Mainly Europe)
- Saftronics VG10 – Basic Connection Diagram to PLC (Source Logic, Mainly Europe)
- Saftronics PC10 (Obsolete) AC Drives
- Saftronics PC10 – Options & Accessories
- Saftronics PC10 – SF-10 Ethernet Module Kit
- Saftronics PC10 – 24 VDC or 24/120 VAC Input + Relay Option Card
- Saftronics PC10 – 24 VDC or 24/120 VAC Interface Card Kit (PC10, GP10, or VG10 Inverter)
- Saftronics PC10 – Relay Output Card
- Saftronics PC10 – HMI Pump Controller
- Saftronics PC10 – PC10 120 VAC Option Card
- Saftronics PC10 – Palm Pilot Saflink Kit
- Saftronics PC10 – Dynamic Braking
- Saftronics PC10 – Drive Ratings Efficiency and Watts Loss
- Saftronics PC10 – Standard Specifications
- Saftronics PC10 – Part Number: PC102F12-9, PC102F25-9, PC102F50-9 & PC102001-9
- Saftronics PC10 – Part Number: PC102002-9, PC102003-9, PC104F50-9, PC104001-9, PC104002-9 & PC104003-9
- Saftronics PC10 – Part Number: PC102005-9 & PC104005-9
- Saftronics PC10 – Part Number: PC102007-9, PC102010-9, PC104007-9 & PC104010-9
- Saftronics PC10 – NEMA 1 Kit Dimensions
- Saftronics PC10 – Basic Wiring Diagram
- Fincor 5700 Series (Obsolete) AC Drive
- Fincor 5740 Series (Obsolete) AC Drive
- Fincor 5750 Series (Obsolete) AC Drives
- Motortronics Soft Starters
- SOLCON Soft Starters
- SOLCON RVS-DN Digital Soft Starter with Advanced Motor Protection
- Solcon HRVS-DN Digital Soft Starter with Advanced Motor Protection
- Solcon HRVS-TX Digital Transformer Soft Starter
- SOLCON RVS-AX Analog Soft Starters
- SOLCON Solstart Plus Analog Soft Starters
- SOLCON RVS-BX Basic Soft Starter with Built-In Bypass
- SOLCON RVS-DX Digital Soft Starter with Built-In Bypass
- SOLCON RVS-EX Digital Soft Starter for Explosion Proof motors with Built-In Bypass
- SOLCON SEM-N Rugged Soft Starter for Naval and Military Specifications
- SOLCON SOLSTART Miniature Analogue Soft Starter
- SOLCON SOLSTART 1P Single Phase Analogue Soft Starter
- SOLCON SOLBRAKE DC Injection Brake Soft Starter
- Magnetek – Soft Starters
- WEG Variable Frequency Drives, Controls and Motors
- ABB ACS150 Component Drives :: Overview
- DC Variable Speed Drives
- DC Drive Fundamentals
- ABB DCS 400 Digital DC Converter Drive
- ABB DCS 500 DC Drive
- ABB DCS800 DC Drives Overview
- DCS800 – Power Converter Modules
- DCS800 Panel Drive
- DCS800 Enclosed Converters
- DCS800 Rebuild and Upgrade Kits
- Adaptive Programming and Start-up Assistants
- DriveWindow Light – Startup and Maintenance Tool
- DCS800 Commissioning Macros
- DCS800 Firmware
- DCS800 Technical Specifications
- Current Ratings – Modules – Non-Regenerative
- Current Ratings – Modules – Regenerative
- Current Ratings – Modules – DCS800-EP Panel Drive
- DCS800 Dimensions and Weights
- DCS800 Technical Diagram
- DCS800 Plug-in Options
- DCS800 Feedback Options
- DCS800 Communication Options – Fieldbus Control
- DCS800 External Field Supply
- ABB DCS800-EP replaces Reliance FlexPak® 3000 – 230V Drive Cross Reference
- ABB DCS800-EP – 460V Drive Cross Reference
- ABB DCS800-EP – Options Cross Reference
- ABB DCS800-EP – Product Differences and Remedies – Hardware
- ABB DCS800-EP – Product Differences and Remedies – Control/Interface & Features
- ABB DCS800-EP – Drive Dimensions
- ABB DCS800-EP – Installation Procedure – Wiring and Configuration
- ABB DCS800-EP – Parameter Cross-Reference
- FINCOR Series 2600/2610 DC Drives
- 50 Amp & 90 Amp DC Field Regulators
- Mentor II | Quantum III | FXM5 Change of Status
- SIMOREG 6RA24 Siemens DC Drive Features
- SIMOREG 6RA70 Siemens Variable Speed DC Drive Description and Base Drive Catalog Numbers
- SIMOREG 6RA70 Siemens DC Drive Features
- SIMOREG 6RA70 DC Master Design & Operation – Converters
- SIMOREG 6RA70 Design & Operation – Parameterization Devices
- SIMOREG 6RA70 Design & Operation – Software Structure
- SIMOREG 6RA70 Design & Operation – Closed-Loop Functions in Armature Circuit
- SIMOREG 6RA70 Design & Operation – Closed-Loop in Field Circuit
- SIMOREG 6RA70 Design & Operation – Optimization Run
- SIMOREG 6RA70 Design & Operation – Monitoring & Disgnosis
- SIMOREG 6RA70 Design & Operation – Functions of Inputs & Outputs
- SIMOREG 6RA70 Design & Operation – Safety Shutdown (E-STOP)
- SIMOREG 6RA70 Design & Operation – Serial Interface
- 1000 Hp DC Variable Speed Drive System
- 3000 Hp DC Variable Speed Drive
- Permanent Magnet DC Motors
- SCR Drive Controllers (SCR-Silicon Controlled Rectifier)
- Custom Electric Control Panel Shop
- GE AC & DC Motors (G.E. Motors – General Electric AC & DC Motor)
- GE X$D Ultra® NEMA Premium Efficiency – TEFC AC Motors
- GE Kinamatic® Explosion Proof AC Motors
- GE Energy Saver® – TEFC Severe Duty AC Motors
- GE Kinamatic® General Purpose AC Motors
- GE Motors Energy Saver NEMA Premium Efficiency – ODP AC Motors
- GE ValueLine™ EPAct Efficiency – TEFC AC Motors
- GE ValueLine™ EPAct Efficiency – ODP AC Motors
- GE Permanent Magnet Custom DC Motors
- GE ValueLine™ Vertical Hollow Shaft AC Motors
- GE Permanent Magnet Standard DC Motors
- GE ASD Inverter Duty AC Motors
- G.E. Permanent Magnet Washdown DC Motors
- Avtron – Drives, Measurement and Tachs
- Avtron – Adjustable Speed Drives and Drive Systems
- Avtron – Speed and Length Measurement
- Avtron – Tachs, Tachometers, Encoders, Rotary Pulse Generators
- Avtron – Sales Literature and Instruction Sheets
- Avtron – Classic Tach Models
- Avtron – Price Quotation Request Form
- Avtron – Tachometers Availability
- Avtron – Heavy, Mill-Duty Encoders
- Avtron – Setting Air Gap on M285 Sensors
- Avtron – M4 Universal Encoder
- Avtron – M56, M67, M85 THIN-LINE
- Avtron – M285QUAD Outline Drawing
- Avtron – Severe Duty Encoders
- Avtron – Mill-Duty Encoders
- Avtron – M3 Universal Encoder
- Avtron – M3 Applications
- Avtron – M3 Installation
- Avtron – M3 Specifications
- Avtron – Tach Accessories
- Avtron – Tach Solutions
- Avtron – Rugged Environments
- Avtron – Selection by Motor Frame Size
- Avtron – Adapter Kits Outline Drawings
- Avtron – Motors with Brakes
- Avtron – NEMA C Face Mounting
- Avtron – Market Specific Applications
- Dynapar Encoders and Tachs
- ACURO AI25 Encoders
- Acuro Series AI25 Absolute Encoder with DeviceNet Interface
- Acuro Series AI25 Absolute Encoder with Profibus Interface
- Acuro Series AI25 Absolute Encoder with Interbus Interface
- Acuro Series AI25 Absolute Encoder with BiSS Interface
- Acuto Series AI25 Optical Encoders with SSI Interface
- Acuro Series AI25 Absolute Encoder with Parallel Interface
- Acuro Series AD25 Drive Absolute Encoder
- Series R25 – Mill Duty, HOUSED Resolver
- Series 21/22 Heavy Duty Incremetal Encoders
- Series H20 Encoder
- Series HA25 Dynapar Heavy Duty Encoders
- Series HR25 Incremental Encoders
- Series HC25 Incremental Encoders
- Series H58 Heavy Duty Encoders
- Series H42 Heavy Duty Encoders
- Series HA725 Indusrtial Duty Encoders
- Series HD20 Optical Encoder
- Series HD25 Optical Encoder – Harsh Duty
- Series H56 Rotopulser Heavy Duty Encoders
- RIM Tach 6200 Digital Tachometer
- Series X25 Incremental Encoders
- Series 60 Rotopulser Incremental Encoders
- Series H20 Hub Shaft Encoders
- Series HSD25 Harsh Duty Optical Encoders
- Series HSD44
- Series HS20 Sealed Hollow Shaft Encoders
- Series HS35 Sealed Hollow Shaft Encoders
- The NEW HS35R
- Series HSD35 Shaftless Optical Encoder
- Series HSD37 Hollowshaft Rotary Encoder
- Series HSD38 Harsh Duty Optical Encoder
- Series DWD38 Heavy Duty Rotary Encoders
- SLIM Tach HS56 Incremental Encoder / Tachometer
- RIM Tach HS85 Digital Tachometer
- SLIM Tach SL56 Rotary Encoder
- SLIM Tach RL67 Incremental Rotary Encoder
- SLIM Tach SL85 Digital Tachometer
- SLIM Tach SL1250 Incremental Encoder
- RIM Tach 8500 Digital Tachometer
- RIM Tach 1250 Digital Tachometer
- Series R45 Rotopulser Incremental Encoders
- ACURO AI25 Encoders
- Spare Parts and Replacement Parts
- PLC (Programmable Logic Controllers)
- Services
- Projects
- Operator Stations by Joliet Technologies
- AC VFD, AC Controllers and DC VSD by Joliet Technologies
- Material Handling Modernization Project by Joliet Technologies
- 10 DC (SCR) Drive System :: Neptune Marine Oil & Gas
- Mermaid Offshore Services :: 4 DC (SCR) Drive Cabinets
- “Frontier Driller” Offshore Oil Rig :: DC (SCR) Drive Bays
- 1000Hp Siemens SIMOREG 6RA70 DC Variable Speed Drive Retro-Fit
- Smurfit-Stone: Corrugator Crew Sets Production Record
- Steel Slitting Line for Braner USA
- 1000HP DC Drive, Bow Thruster Application for Pegler Automation
- 1000HP DC Traction Motor Drive, Slurry Pump Application for Baker Hughes
- Siemens 6RA70 DC Drive and GE 752 Traction Motor to Hallett Materials
- ABB ACS 800 VFD to Applied Synergistic
- Two 200Hp Variable Speed DC Drives and Motors to JHT Electronics
- Substrate Technology Inc. :: Joliet Technologies, L.L.C.
- Wyco Tool Company
- Variable Frequency Drives and Controls for Food Processing and Bakery Machinery
- Information
- Guide to Harmonics with AC Variable Frequency Drives
- Variable Speed Drives – Application Information
- Reducing harmonics caused by variable speed drives
- FAQ – Variable Speed Drives Frequently Asked Questions
- EASA Electrical Engineering Handbook
- Part Winding Start
- 3Ph Motors, Single Speed
- 3Ph Motors, 2 Speed, Single Winding
- Connections for NEMA DC Motors
- Connections for NEMA DC Generators
- Field Polarities of DC Machines
- Maximum Locked-Rotor Currents – Three-Phase Squirrel Cage Motors
- NEMA Code Letters for AC Motors
- General Speed-Torque Characteristics
- Effect of Voltage unbalance on Motor Performance
- Starting Characteristics of Squirrel Cage Induction Motors
- Allowable Starts and Starting Intervals
- NEMA Size Starters for Three-Phase Motors
- Starter Enclosures
- NEMA Size Starters for Single-Phase Motors
- Determining the Polarization Index of Machine Windings
- Formulas for Electrical Motors
- Motor Application Formulas
- Glossary of Terms
- Variable Frequency Drive (VFD) Case Studies
- VFD Case Studies – ABB drives & motors help to launch lifeboats quickly and safely.
- VFD Case Studies – Paperboard mill benefits from using DC drives
- VFD Case Studies – ABB Drive cuts water pumping bill for semiconductor plant.
- VFD Case Studies – Insulation manufacturing process saves energy with ABB :: Joliet Technologies
- VFD Case Studies – ABB drives cut costs at MINI production plant
- VFD Case Studies – Film maker slashes costs with ABB drives
- VFD Case Studies – ABB drive cuts costs for wooden toy company
- VFD Case Studies – Close pump control doubles efficiency for West of Scotland Water
- VFD Case Studies – ABB Energy Appraisal Saves Money :: Joliet Technologies
- VFD Case Studies – Staggering energy savings prove value of professional audit
- VFD Case Studies – Soft starters save costs for mechanical engineers
- NEMA Frame Chart and T-Frame Chart :: Joliet Technologies
- Model 1681 Instruction Manual – Firing Circuits DC SCR Drives
- IGBT – Insulated Gate Bipolar Transistors :: Joliet Technologies
- Blog
Blog
How to Choose a VFD Variable Frequency Drive?
Selecting the right vfd variable frequency drive begins with understanding the motor, load, and operating environment. A drive that works well on a conveyor may perform poorly on a pump or compressor. The motor nameplate provides essential data, including voltage, current, frequency, and rated speed. These details should match the drive’s operating range.
Real-world selection also requires attention to starting torque, acceleration time, braking needs, and daily duty cycles. A dusty workshop may need a higher enclosure rating. A long motor cable can increase electrical stress and electromagnetic interference. Harmonics may affect sensitive equipment nearby. Control requirements matter too. Basic speed control may suit a fan, while closed-loop vector control may support demanding lifting equipment.
Small details matter.
Experienced engineers also check overload capacity, ambient temperature, cooling space, and local service availability. Manufacturer manuals, technical datasheets, and verified application guidance provide stronger evidence than sales claims alone. Installation quality remains important. Even a well-sized drive can fail early when ventilation is blocked or grounding is neglected.
There is no perfect choice for every project. Cost, efficiency, reliability, and future expansion often conflict. A slightly oversized drive may improve flexibility, but it can increase purchase and installation costs. An undersized model may overheat during repeated starts. Careful comparison reduces these risks. This guide explains the practical questions behind each specification, helping readers choose a dependable drive with fewer surprises. Some applications still require review by a qualified electrical professional.
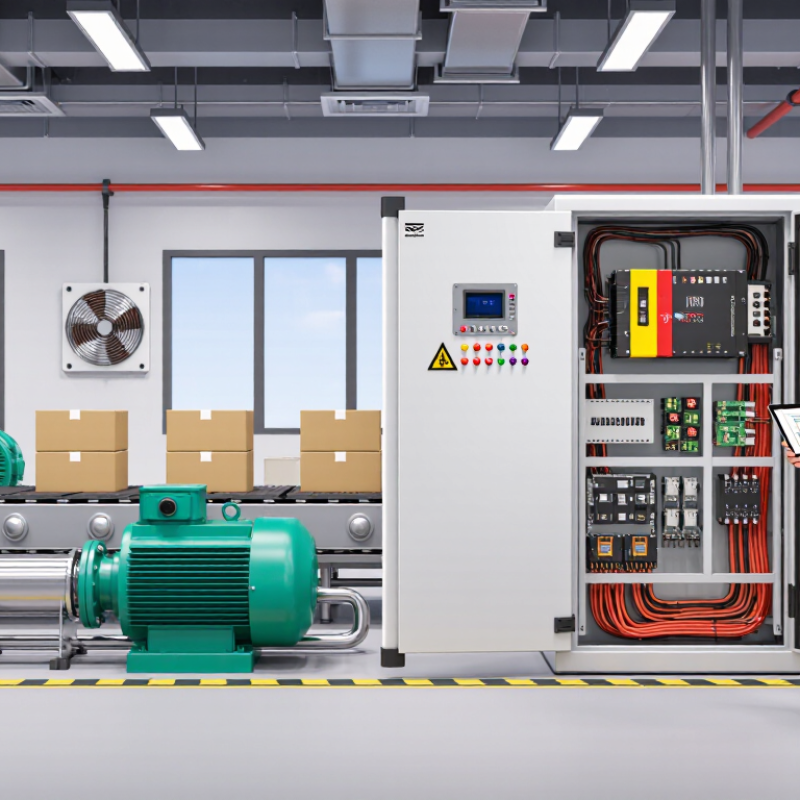
Define the Motor Load, Speed Range, and 50/60 Hz Power Requirements
Choosing a VFD begins with the motor load, not the enclosure or display. In field commissioning, I record whether the machine needs constant torque, variable torque, or high starting torque. A loaded conveyor may demand nearly full torque at low speed. A centrifugal fan usually needs less torque as speed falls. This difference affects drive sizing, overload capacity, and cooling. Measure the actual current during startup and normal operation. A nameplate value alone can mislead. Keep measurements.
Define the required speed range in real operating conditions. A motor running from 15 to 60 Hz behaves differently from one running between 40 and 90 Hz. At low frequency, verify motor cooling, available torque, and minimum stable speed. Above base frequency, torque commonly declines as voltage reaches its limit. Check acceleration time, braking needs, and load inertia before selecting the drive. A heavy mixer needs more patience. It may need a braking resistor or a larger drive. I once trusted a calculated ramp time that ignored product buildup; the motor tripped after several cycles. That mistake changed how I validate field data.
Confirm whether the supply is 50 or 60 Hz, then match voltage, phase, and motor ratings. Frequency affects base speed, pump flow, fan output, and line current. A 50 Hz motor operated on a 60 Hz system may require careful voltage and torque review. Check harmonics, ambient temperature, altitude, and panel ventilation. Leave practical capacity for overloads, voltage variation, and future process changes. Do not oversize blindly. An oversized drive can reduce control quality and raise cost. Record every assumption before approval.
How to Choose a VFD Variable Frequency Drive?
Define the Motor Load, Speed Range, and 50/60 Hz Power Requirements
This chart compares three common motor load characteristics using rated motor torque as 100%. Constant-torque loads, such as conveyors and positive-displacement pumps, require approximately the same torque throughout the speed range. Variable-torque loads, such as centrifugal pumps and fans, follow the affinity laws: torque is proportional to the square of speed and power is proportional to the cube of speed. Constant-power loads require decreasing torque as speed rises, which is common above base speed in some machine tools and winding applications.
For a four-pole motor, the theoretical synchronous speed is 1,500 rpm at 50 Hz and 1,800 rpm at 60 Hz. Actual induction-motor speed is slightly lower because of slip. Select the VFD according to the motor nameplate voltage, current, rated power, required speed range, overload demand, and whether the application requires constant-torque or variable-torque operation.
Calculate VFD Size from Motor kW, FLA, and 110–150% Overload Ratings
How to Choose a VFD Variable Frequency Drive?
VFD sizing starts with the motor nameplate, not kW alone. Check rated voltage, frequency, full-load amperes (FLA), speed, and duty class. A 30 kW motor rated at 400 V may show an FLA near 58 A, but actual values vary. Select a drive with continuous output current at least equal to 58 A. Then calculate overload capacity: 58 × 1.10 = 63.8 A for lighter variable-torque duty, or 58 × 1.50 = 87 A for demanding starting and acceleration. Check the application carefully.
That distinction matters. Fans and pumps often need about 110% overload, while conveyors, mixers, and loaded compressors may require 150% for short periods. IEC 61800-5-1 and IEC 60034-1 provide important safety and motor-performance references, but the drive’s stated overload duration still controls selection. A rating such as 150% for 60 seconds is not equal to 150% continuously.
The International Energy Agency has estimated that electric motor systems consume roughly 43–46% of global electricity. The U.S. Department of Energy has also reported that motor-driven equipment represents about 70% of industrial electricity use. Small sizing errors can therefore waste substantial energy or cause nuisance trips. Consider altitude, ambient temperature, enclosure cooling, cable length, and switching frequency. I sometimes see kW-only selections pass initial testing, then fail during cold starts. Recheck the real load profile.
Match Control Method: V/f, Sensorless Vector, or Closed-Loop Vector
Choosing a VFD starts with the control method, not the keypad features. During commissioning, check motor data, load behavior, speed range, and stopping demands. V/f control suits fans, pumps, and conveyors with modest torque variation. It adjusts voltage with frequency. Keep expectations realistic. At very low speed, torque regulation may weaken, especially with an incorrectly tuned motor model.
Sensorless vector control estimates rotor position from electrical feedback inside the drive. It usually delivers stronger starting torque and better speed holding without an encoder. This suits mixers, conveyors, and changing loads. Motor identification matters. A rushed auto-tune can cause unstable current or disappointing low-speed performance. I have seen users blame the drive when incorrect nameplate values caused the real problem.
Closed-loop vector control adds an encoder or resolver for direct speed feedback. It fits applications requiring precise speed, near-zero-speed torque, or rapid reversal. Consider it for tension systems, positioning axes, and demanding lifting equipment. Wiring quality matters. Shielding, grounding, and pulse resolution can affect results. The most expensive method is not automatically the best. A simpler V/f setup may run cooler and need less maintenance, but only when its limits match the machine.
How to Choose a VFD Variable Frequency Drive? - Match Control Method: V/f, Sensorless Vector, or Closed-Loop Vector
| Evaluation Dimension | V/f Control | Sensorless Vector Control | Closed-Loop Vector Control |
|---|---|---|---|
| Control principle | Maintains a programmed voltage-to-frequency ratio to regulate the motor’s magnetic flux. | Uses a motor model and measured current to estimate rotor position and regulate torque and flux without a shaft encoder. | Uses vector control together with an encoder or equivalent feedback device to measure actual shaft speed or position. |
| Required feedback | Normally no speed or position feedback. | No encoder is normally required; performance depends on motor data and estimation algorithms. | Requires an encoder, resolver, or another compatible speed/position feedback device and interface. |
| Typical speed regulation | Approximately 1–3% of base speed in practical open-loop applications; load slip can affect accuracy. | Typically about 0.5–1% of base speed, depending on drive setup, motor parameters, and operating conditions. | Commonly about 0.01–0.1% of base speed when correctly installed and commissioned. |
| Low-speed torque | Limited at very low speed unless special boost or application-specific settings are used. | Good low-speed torque for many constant-torque and moderate-duty applications. | Strong and highly controllable low-speed torque, including near-zero-speed operation when the system is properly tuned. |
| Torque response | Basic response; torque changes are generally slower and less precise. | Fast torque response suitable for acceleration, deceleration, and changing loads. | Fastest and most precise torque response because actual shaft feedback closes the control loop. |
| Position control | Not suitable for accurate position control. | Generally unsuitable for precise positioning because rotor position is estimated rather than directly measured. | Suitable for positioning, registration, indexing, and electronic line-shaft applications when the drive supports these functions. |
| Starting under load | Acceptable for pumps, fans, and light-to-moderate starting loads; heavy breakaway torque may be difficult. | Good capability for conveyors, mixers, compressors, and other loads requiring higher starting torque. | Best choice for heavy starting loads, hoists, elevators, and applications requiring controlled torque at standstill. |
| Commissioning effort | Low. Motor nameplate data and basic acceleration/deceleration settings are usually sufficient. | Moderate. Accurate motor nameplate data, auto-tuning, and correct application parameters are important. | High. Encoder installation, feedback polarity, alignment, tuning, and mechanical coupling must be verified. |
| System complexity | Low; fewer components and fewer feedback-related failure points. | Medium; software-based motor estimation reduces hardware requirements but requires better parameter setup. | High; includes feedback hardware, cabling, shielding, installation, and maintenance requirements. |
| Energy performance | Efficient for variable-torque loads when speed is reduced, but motor flux may be less optimized at light load. | Can improve motor efficiency and torque utilization across a wider operating range through flux and torque regulation. | Similar vector-control efficiency benefits; additional feedback hardware introduces small system losses and maintenance needs. |
| Typical applications | Centrifugal pumps, fans, blowers, simple conveyors, and applications with low precision requirements. | Conveyors, mixers, extruders, compressors, machine tools, and general-purpose constant-torque machinery. | Hoists, elevators, cranes, winding machines, precision conveyors, servo-like speed control, and positioning systems. |
| Cost level | Usually the lowest total system cost because no encoder is required. | Usually a medium total system cost with no encoder, but setup and commissioning may require more engineering time. | Usually the highest total system cost because of the feedback device, cabling, interface, and commissioning requirements. |
| Main advantages | Simple, economical, easy to maintain, and sufficient for many variable-speed applications. | Balances strong performance, good torque control, and moderate system complexity without an encoder. | Provides the highest speed accuracy, torque precision, dynamic response, and low-speed control. |
| Main limitations | Lower speed and torque accuracy, limited low-speed performance, and no direct position feedback. | Performance can vary with motor temperature, parameter accuracy, load changes, and very low-speed operation. | Higher cost and complexity; feedback wiring and encoder alignment require careful installation and maintenance. |
| Recommended selection rule | Choose V/f when the application mainly needs economical speed control and does not require high torque or accuracy. | Choose sensorless vector when good torque and speed regulation are needed but an encoder is undesirable or impractical. | Choose closed-loop vector when precise speed, high starting torque, near-zero-speed control, or positioning is essential. |
Note: Performance figures are typical planning ranges rather than guaranteed values. Actual results depend on motor type, drive capacity, tuning, load characteristics, feedback resolution, installation quality, and operating conditions.
Select Voltage, IP Rating, and Harmonic Limits Under IEC 61800 Standards
How to Choose a VFD Variable Frequency Drive?
Selecting a VFD starts with voltage, not horsepower alone. Confirm the incoming supply, phase arrangement, motor voltage, and allowable frequency range. A mismatch can cause overheating, nuisance trips, or weak starting torque. IEC 61800 safety requirements support careful insulation, protection, and installation decisions. I always compare the drive’s continuous current rating with the motor nameplate current. The number on a sales sheet is not enough.
IP rating matters where the VFD operates. A dusty workshop may need more protection than a clean control cabinet. Moisture, oil mist, and washdown conditions also change the decision. IP54 can suit some enclosed areas, while harsher locations may require a higher rating or a separate cabinet. Do not assume a higher IP rating solves heat problems. Sealed enclosures often retain heat. That detail is easy to miss.
Tips: Check IEC 61800-3 EMC requirements, then review local harmonic limits. Harmonic current depends on the drive, load, transformer, and other equipment. Measure the existing system when possible. Consider line reactors, passive filters, or active solutions only after an assessment. A simple six-pulse drive may be acceptable in one facility and unsuitable in another. I have seen harmonic concerns blamed on the VFD alone, although the real issue was a crowded electrical network. Leave space for airflow, verify grounding, and document the final settings. Some selections look correct on paper. Field conditions can disagree.
Estimate Pump and Fan Savings Using the Affinity Law: Power ∝ Speed³
How to Choose a VFD Variable Frequency Drive?
The affinity law makes pump and fan savings easier to estimate. For similar operating conditions, power is proportional to speed cubed. At 80% speed, power becomes 0.8³, or 51.2% of full-speed power. A 10 kW motor could therefore use about 5.1 kW. That is nearly 49% lower power demand before considering drive and motor losses. The U.S. Department of Energy’s Pumping System Sourcebook identifies this relationship as a key method for evaluating variable-speed control.
power becomes
51.2% of full-speed power.
The calculation is simple. Reality is not. Static head, minimum flow, leakage, and poor system design can reduce savings. A fan serving a clean filter may respond well, while a pump lifting water to a fixed elevation may respond poorly. The DOE Fan System Assessment Tool guidance also emphasizes measuring actual airflow, pressure, and operating hours instead of trusting nameplate data. Field readings matter.
Choose a VFD after recording motor current, voltage, load profile, and required speed range. Check overload capacity, enclosure rating, braking needs, and harmonic conditions. Use measured data from a clamp meter and pressure gauge. Do not size only by horsepower.
A useful estimate.
If a 15 kW pump runs at 70% speed, the ideal power ratio is 34.3%. However, real input power may be higher because of efficiency losses and static lift. The European Commission’s Ecodesign studies report that motor-driven systems represent a major share of electricity use, making small control improvements valuable. My own engineering preference is cautious: calculate first, then verify savings after commissioning.
= 34.3% ideal power ratio
Related Posts
-
Top 10 Types of Variable Frequency Drives
-
What Is a VFD Variable Frequency Drive and How Does It Work?
-
2026 Top Variable Frequency Drive Types?
-
How to Choose the Right VFD Variable Frequency Drive?
-
What Is a Frequency Drive and How Does It Work?
-
Top 10 AC Motor Speed Controllers to Enhance Your Efficiency in 2023