Finding the right Mcb Assembly Robot for sale in 2026 takes more than comparing prices or production-speed claims. The best choice depends on your breaker design, target output, available floor space, and required assembly steps. A machine suited to one factory may not fit another. There is no universal winner.
A reliable evaluation starts with the actual process. Check which components the robot handles, how it positions and fastens parts, and whether operators can change models without lengthy downtime. Ask suppliers for cycle-time assumptions, supported product ranges, safety features, and details about installation and after-sales service. Request a sample run using representative components, then inspect alignment, fastening consistency, and rejected units. Small details matter. A clear wiring diagram and accessible maintenance points can affect daily operation more than a polished brochure.
For a practical shortlist, compare the complete system, not just the robot arm. Review included fixtures, inspection equipment, software, training, spare parts, and warranty terms. Confirm that stated performance matches your product and production conditions. Do not treat an attractive demonstration as proof of long-term reliability. Not every factory needs full automation. A partly automated line could be the better fit, though it may not look as impressive in a presentation. This guide will help buyers ask sharper questions and weigh trade-offs before requesting quotations. The most useful recommendation is an honest one: verify the details with your own samples, operators, and production targets.
IEC 60898-1 defines requirements for household and similar-use AC circuit-breakers, including miniature circuit-breakers (MCBs). Its scope includes rated currents up to 125 A and rated short-circuit capacities up to 25 kA. These are upper limits, not ratings every MCB must meet. Check the product’s marked values and applicable test documentation before setting assembly parameters.
For an MCB assembly robot, the standard’s scope helps define which product families and test requirements the line must support. A 6 A unit and a 100 A unit may need different component handling, screw settings, and inspection recipes. Confirm these details with engineering before comparing machines for sale. That distinction matters. Ask suppliers how the system verifies terminal torque, detects missing parts, and records results for each unit. A practical trial should include changeovers and fault checks, not just a short run of identical breakers. A tidy cycle-time chart can still hide rework or missed inspections. I would also review the robot’s actual compatibility with the MCB designs being produced; the standard alone does not specify a machine’s capabilities.
| Topic | IEC 60898-1 Scope or MCB Detail | Assembly Automation Consideration | What to Verify |
|---|---|---|---|
| Product covered | Air-break circuit-breakers for overcurrent protection in household and similar installations, operating on AC. | Configure the assembly process for the specific MCB construction, pole count, and component layout. | Product drawings, bill of materials, and applicable standard requirements. |
| Rated current | Rated current is within the standard’s scope up to 125 A. | Use product-specific tooling and recipes for each current-rated model; do not treat current rating as a robot payload or speed specification. | Nameplate rating and the approved product configuration. |
| Rated short-circuit capacity | The standard’s scope includes rated short-circuit capacity up to 25 kA. | Assembly automation can support consistent component placement, but it does not establish or certify the breaker’s short-circuit performance. | Required product tests and the declared rating for the finished model. |
| Rated voltage | Rated voltage is within the standard’s scope up to 440 V AC between phases. | Maintain traceability between the assembled configuration and its intended voltage rating. | Product marking, circuit configuration, and technical documentation. |
| Protection functions | MCBs covered by the standard provide protection against overcurrent, including overload and short-circuit conditions. | Automated assembly checks may verify the presence and positioning of specified parts; functional protection performance needs appropriate testing. | Inspection plan and required electrical and mechanical tests. |
| Typical assembly operations | Operations depend on the product design and are not prescribed as a particular robot configuration by IEC 60898-1. | Potential tasks include component feeding, positioning, fastening, marking, and handling between stations. | Part presentation, cycle requirements, changeover needs, and station layout. |
| Quality checks | Compliance applies to the finished circuit-breaker and its required performance, not simply to the assembly equipment. | Consider presence checks, orientation checks, fastening verification, and production data recording where suitable. | Define acceptance criteria and validate the inspection method against the product requirements. |
| Robot selection | IEC 60898-1 defines MCB product scope; it does not specify a “best” assembly robot. | Select automation based on part size, required handling accuracy, cycle time, tooling, safety, and integration requirements. | Run a process trial using representative parts and confirm the complete line’s safety and quality controls. |
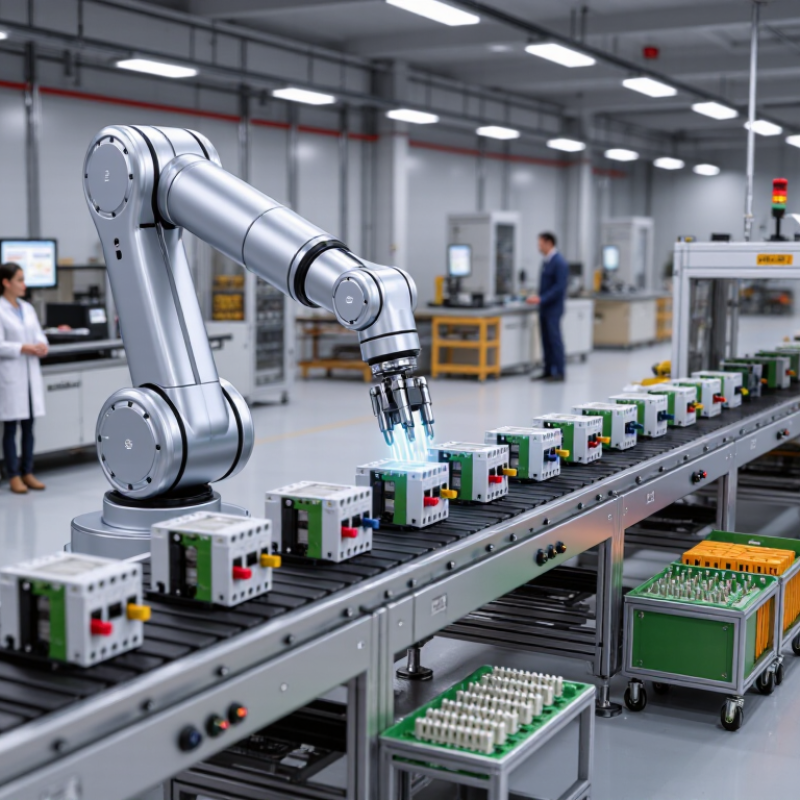
A capable MCB assembly robot should make its sequence visible, not hide it behind a cycle-time figure. Feeding systems orient housings, contacts, springs, and screws before parts reach the fixture. Vision checks can catch reversed components early. During contacting, controlled insertion helps protect terminal alignment and records force or position deviations. Small details matter. A contact that appears seated may still shift during handling.
Riveting needs a repeatable stroke and force, with tooling that avoids marking the housing. Calibration can verify mechanism travel or trip settings against the product specification. Electrical and mechanical tests should then confirm continuity, insulation performance, and operation under defined conditions. A useful line logs results by unit and flags failures instead of hiding them in averages. The sequence is not always linear: test failures may point back to feeder alignment, contact insertion, or rivet force. That feedback loop matters more than a fast demonstration. When evaluating a machine for sale, ask to see representative parts, changeover steps, reject handling, and traceable test records. Numbers can look impressive. Real production also brings dust, worn tooling, and component variation, so a trial run should expose those conditions before purchase.
Compare Robot Cells by Payload, Reach, Cycle Time, and Changeover
Choosing an MCB assembly robot starts with the whole task, not the arm’s headline specifications. Payload must include the gripper, cables, and part; a small feeder or camera can change the calculation. Check reach around the actual fixture, especially where terminals sit behind guards. IFR’s World Robotics 2024 report recorded 541,302 industrial robots installed worldwide in 2023. That figure covers many industries, not MCB production, but it shows why comparing complete cells matters more than comparing robot arms alone.
Ask suppliers to demonstrate the target sequence using representative breakers, trays, and fasteners. Measure cycle time from part presentation through placement, fastening, and inspection. Include pauses for feeding and fault recovery; an impressive motion-only time can mislead. For changeover, record minutes to switch models, replace tooling, load a recipe, and verify the first good unit. Small details matter. One awkward cable can erase a theoretical speed advantage. A short on-site trial is more useful than a polished estimate, though it may still miss rare jams.
Tips: Bring two product variants and a real tray layout to the trial. Confirm payload at the wrist, usable reach at each operation, and sustained cycle time over repeated runs. Ask operators to perform a changeover themselves. Note every manual adjustment. If the comparison feels imperfect, say so—and capture what remains untested.
2026 Best MCB Assembly Robot for Sale?
Check Safety Compliance Against ISO 10218 and IEC 60204-1
For an MCB assembly robot, safety checks should cover the complete work cell, not just the robot arm. ISO 10218 provides requirements for industrial robot safety, including integration considerations. IEC 60204-1 addresses electrical equipment of machinery. Confirm the applicable editions and local requirements with a qualified safety professional. Then review the cell’s risk assessment, guarding, interlocked access doors, emergency stops, and safe stopping behavior. Test these functions under realistic conditions, including a jammed feeder or an operator opening a gate.
Tips: Ask for the risk assessment and electrical drawings. Check protective bonding, circuit protection, and clear wire labels. Watch a stop test in person.
A certificate alone does not show how the installed system behaves. Observe a full production cycle, then verify that access remains controlled during setup and fault recovery. Pay attention to pinch points near the feeder and exposed wiring inside the control cabinet. Record test results and unresolved issues before acceptance. A small gap can matter: a door switch may work during a demo but fail after repeated use. Build periodic checks into the maintenance plan, and revisit the assessment when tooling or the cell layout changes.
IEC 60204-1 defines stop categories 0, 1 and 2. The chart shows their category numbers—not safety scores or a ranking of robot systems.
Category 0: stop by immediate removal of power to the actuators. Category 1: controlled stop, followed by removal of power. Category 2: controlled stop with power remaining available. For an MCB assembly robot cell, verify the selected stop functions and the complete cell design against the applicable editions of ISO 10218 and IEC 60204-1, including the risk assessment and validation.
Estimate Cost per Unit Using Uptime, Yield, and Production Rate
A robot’s quoted price does not reveal its real cost per MCB. Estimate saleable output before comparing machines. Use this formula:
If a cell runs 16 hours daily, handles 30 units per minute, achieves 85% uptime, and yields 98%, it produces about 23,990 good units per day. These are planning estimates, not guarantees. Confirm rate and yield using your product, tooling, and inspection requirements.
Divide daily operating costs by good units, then add the robot’s allocated purchase cost, integration, maintenance, and tooling. For example, $1,200 in daily operating costs across 23,990 good units is about five cents per unit, before equipment and other costs. Low uptime raises unit cost quickly. A faster machine may still lose if changeovers, jams, or rejects reduce output. Ask for documented cycle-time tests and clarify what the supplier includes in rated production. Real factory results can be messier than a proposal.
Tips: Track downtime by cause, not just as one percentage. Verify yield with a representative production run, and include setup losses. Keep a small contingency; early estimates are often too optimistic.